 /GTWeb
Inverted Pendulum Project Log #1
Work-in-progress living document
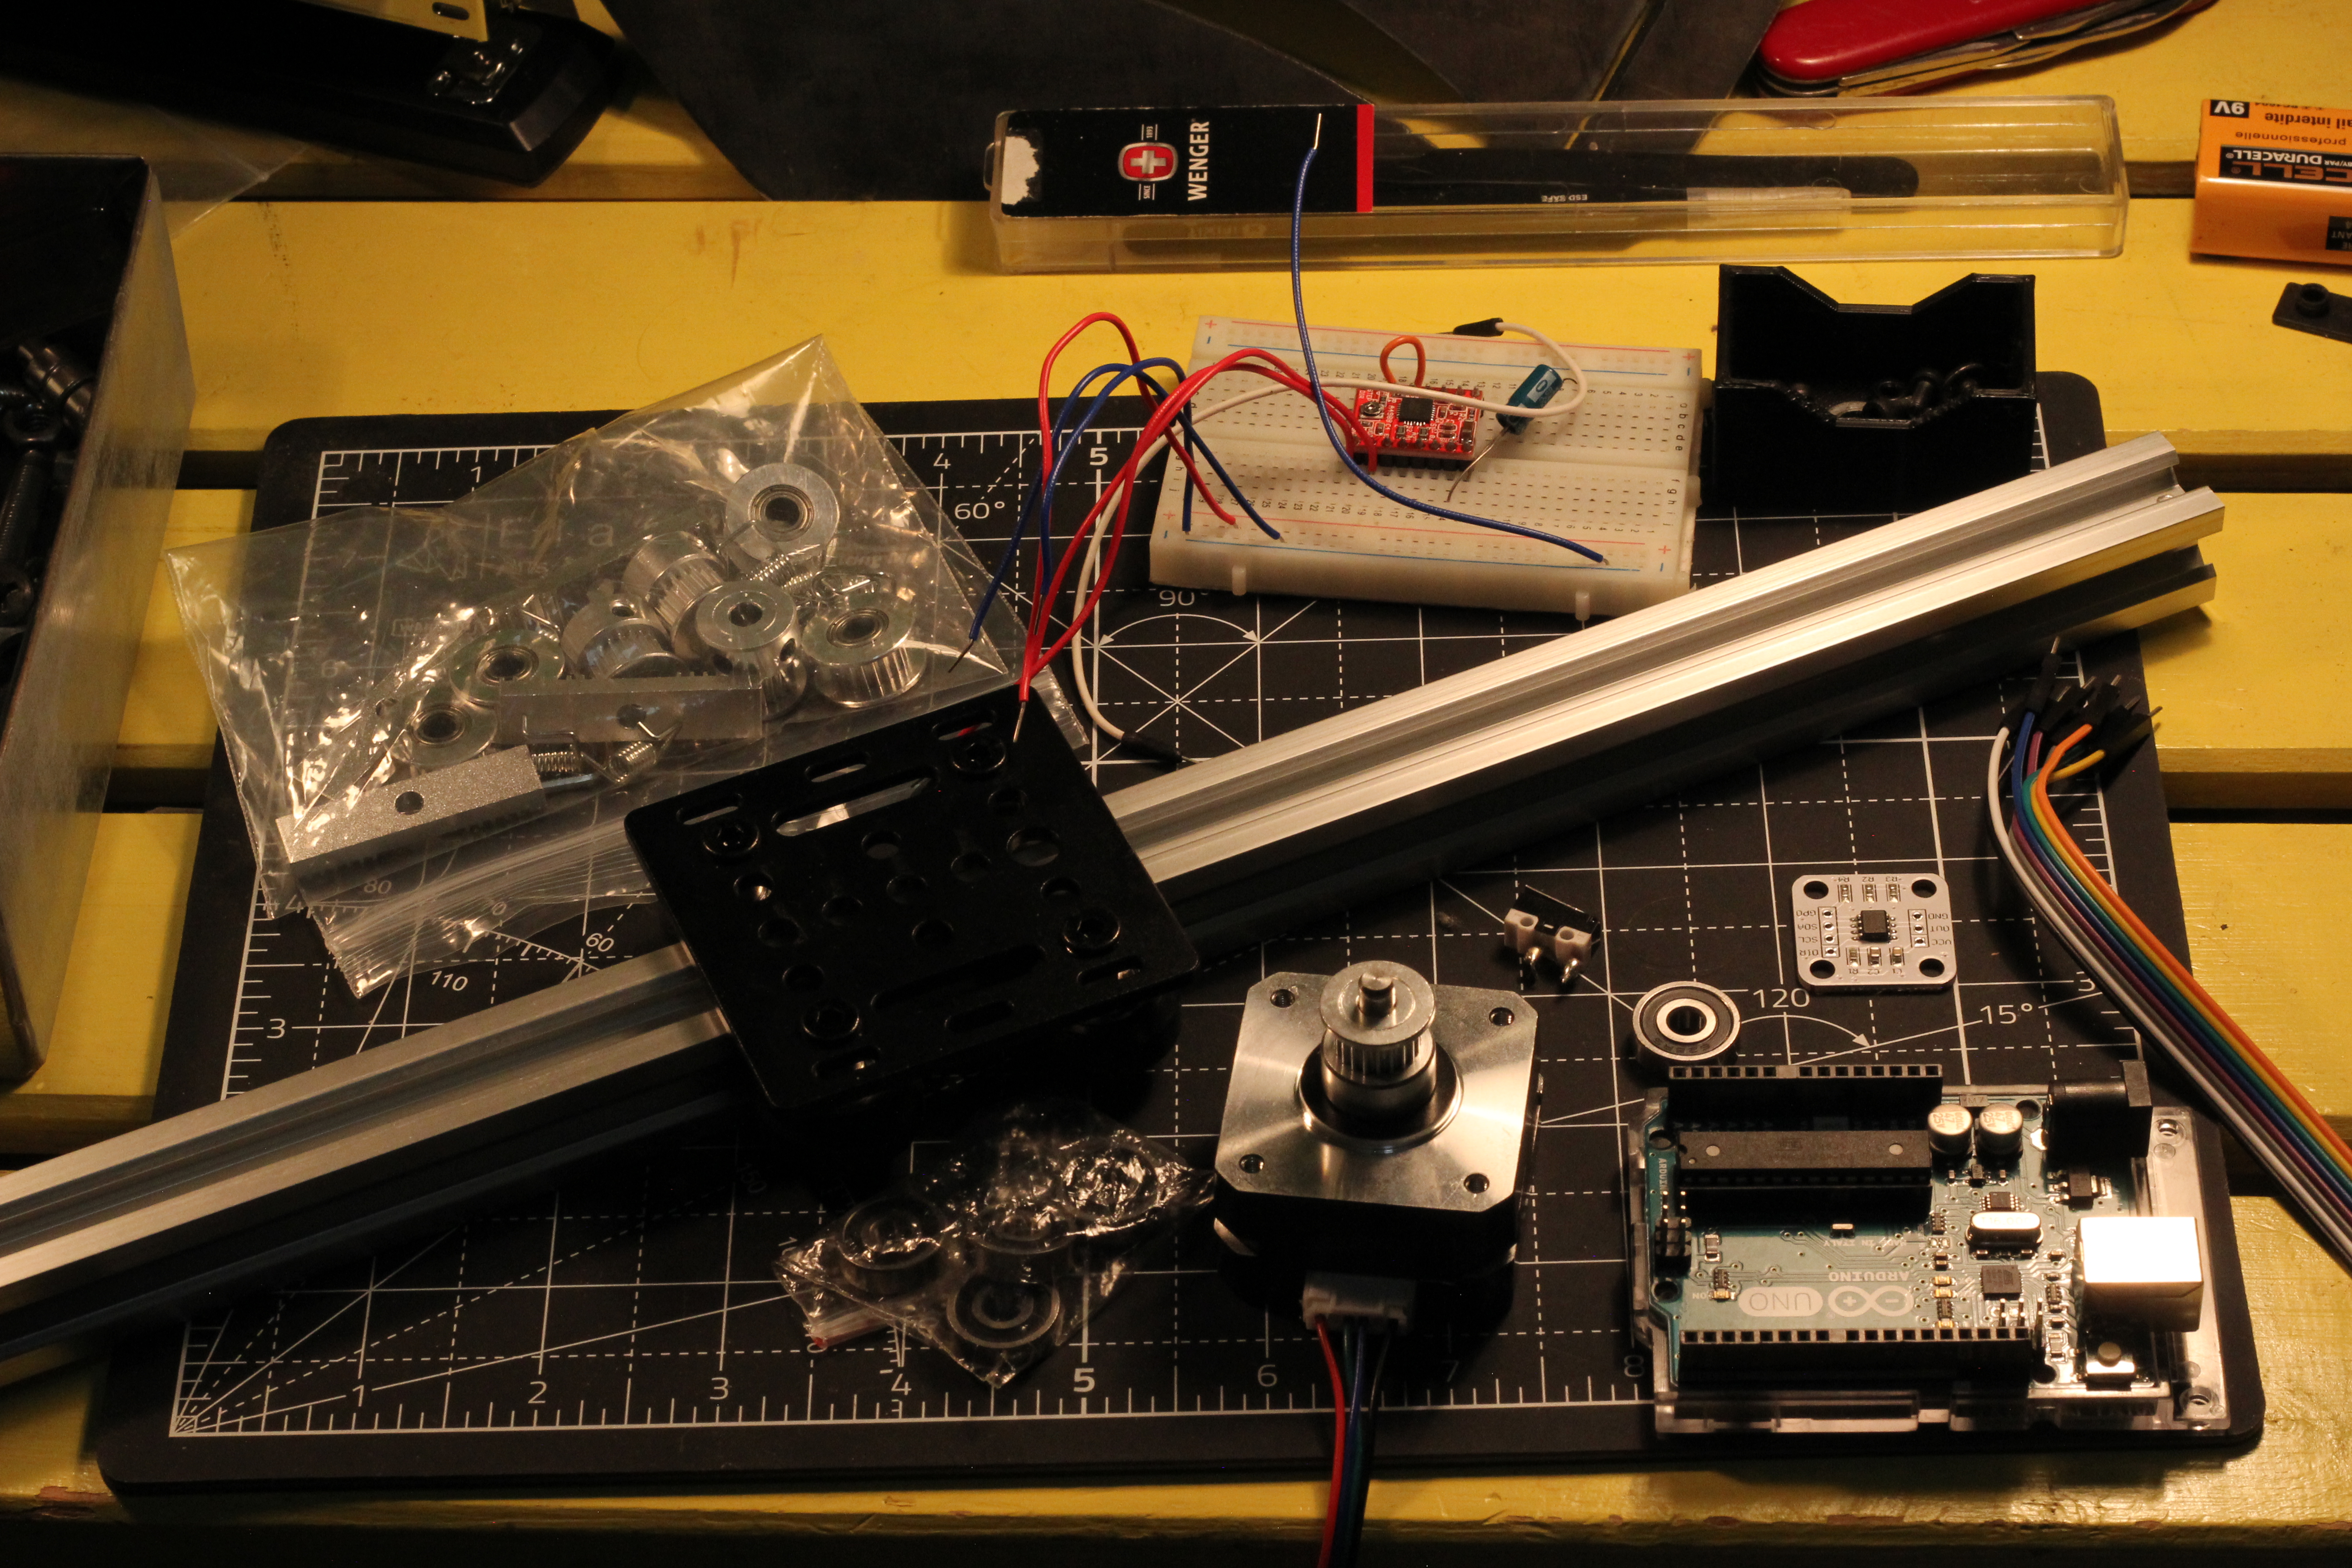
2020 aluminum extrusion gantry & parts
Inspiration
Having recently studied robotics in greater depth, I wanted to begin a project that would apply my knowledge of control theory—the science of making machinery bend to your will to using sensors and physics.
This led me to the perfect choice—an inverted pendulum. It’s a wonderful Renaissance engineering challenge, featuring a bit of everything: mechanical design, motor control, sensors, and simulation.
For inspiration on how to make this happen, I looked to others’ previous attempts:
- Philippe Francois implemented CTMS’ wonderfully-detailed inverted pendulum model.
- Ian Carey (nice site btw) had a very helpful bill of materials, pointing me to the widely-used GT2 timing belt (same as most 3D printers!) as a drive mechanism.
Bill of Materials
| Part | Quantity | Link |
|---|---|---|
| 42x42x23mm Nema 17 Stepper Motor (17HS08-1004S) | 1 | Amazon |
| A4988 Stepper Motor Driver | 1 | DigiKey |
| 400mm 2020 Aluminum Extrusion | 1 | Amazon |
| 2020 V-Slot Gantry | 1 | Amazon |
| AS5600 Magnetic Encoder | 1 | Amazon |
| GT2 Timing Belt + Timing Pulley | 1 | Amazon |
| 625-2RS Ball Bearing | 2 | Amazon |
| SPST Limit Switch | 1 | N/A |
| Arduino Uno Rev3 | 1 | Arduino |